Kango Yanagida Presented at the 44th Annual Conference of the Robotics Society of Japan (RSJ2026)
2026年9月3日
·
1 min read
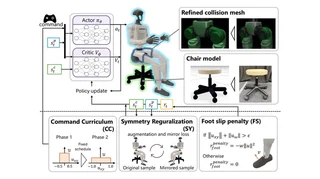
Kango Yanagida of our lab gave the following presentation at the 44th Annual Conference of the Robotics Society of Japan (RSJ2026, September 1–4, 2026, Kanazawa University Kakuma Campus).
[2A2-01] Seated Locomotion of a Humanoid Sitting on a Mobile Chair (in Japanese) Kango Yanagida (Osaka Univ.), Kazuki Miyazawa (Osaka Univ.), Takato Horii (Osaka Univ. / IRCN, The University of Tokyo) September 3, 2026 (Thu), 10:20– Organized Session “Physical AI in the Era of Foundation Models”
Related paper: Stay Seated: Learning Omnidirectional Humanoid Locomotion on a Passive Mobile Chair with Casters (arXiv:2608.28090)
For details, see the RSJ2026 official website.

Authors
Takato Horii
(he/him)
Associate Professor
Associate Professor at Graduate School of Engineering Science, Osaka University.
Research interests include cognitive developmental robotics, computational modeling
of emotional development, and human-robot interaction.