Talk at the NYU CREO Seminar Series
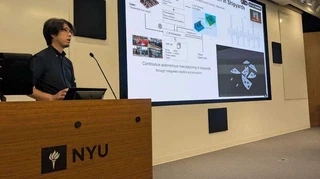
On October 2, 2026, I gave a talk titled “From Language to Coordination: Multi-Robot Task Planning with LLMs and Optimization” at the NYU CREO Seminar Series, NYU Tandon School of Engineering, New York. Kento Kawaharazuka also spoke at the same seminar on “Musculoskeletal Humanoids, Wire-Driven Robots, and Beyond.”
The talk covered multi-robot task planning and coordination that combines large language models (LLMs) with optimization, centered on LiP-LLM, which integrates linear programming and dependency graphs with LLMs for multi-robot task planning. I also discussed applications such as integrating robots and simulation in shipyards.
Great questions from the audience led to lively discussions. Many thanks to Nana Obayashi and Kento Kawaharazuka for inviting me!
