Kango Yanagida's Paper Accepted at Humanoids 2026
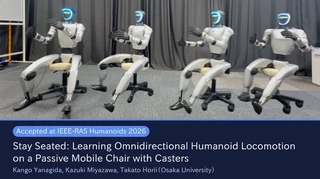
A paper by Kango Yanagida of our lab has been accepted at the 2026 IEEE-RAS 25th International Conference on Humanoid Robots (Humanoids 2026), to be held in December 2026 in Santa Clara, California, USA. This year, 130 of 338 submissions were accepted (acceptance rate 38.5%).
Stay Seated: Learning Omnidirectional Humanoid Locomotion on a Passive Mobile Chair with Casters Kango Yanagida (Osaka Univ.), Kazuki Miyazawa (Osaka Univ.), Takato Horii (Osaka Univ. / IRCN, The University of Tokyo)
In this work, a humanoid robot learns omnidirectional seated locomotion: it stays seated on an ordinary office chair with casters and pushes off the floor with its feet to move forward, backward, sideways, and turn. The chair has no motors, and the policy uses only the robot’s proprioception and a velocity command, with no chair pose, wheel state, or contact sensing. The policy is trained in simulation and transferred zero-shot to a Unitree G1. Just as people delegate weight support to a chair during desk work, this is a first step toward seated loco-manipulation for humanoids.
This work was also presented at the 44th Annual Conference of the Robotics Society of Japan (announcement). For details, see the Humanoids 2026 official website and arXiv:2608.28090.
